


Introduction: Why Navigation Is the Hardest Problem Underwater
Navigation underwater is fundamentally different from navigation in the air or on land.
GPS signals do not penetrate water effectively. Visibility is often limited by turbidity, suspended particles, and light attenuation. Currents introduce drift. Structures such as pipelines, bridge piers, net cages, dam walls, and submerged debris create unpredictable obstacles.
In our years of engineering and field deployment of underwater robotic systems, we have learned that propulsion power alone is not what determines performance. The real breakthrough lies in navigation intelligence.
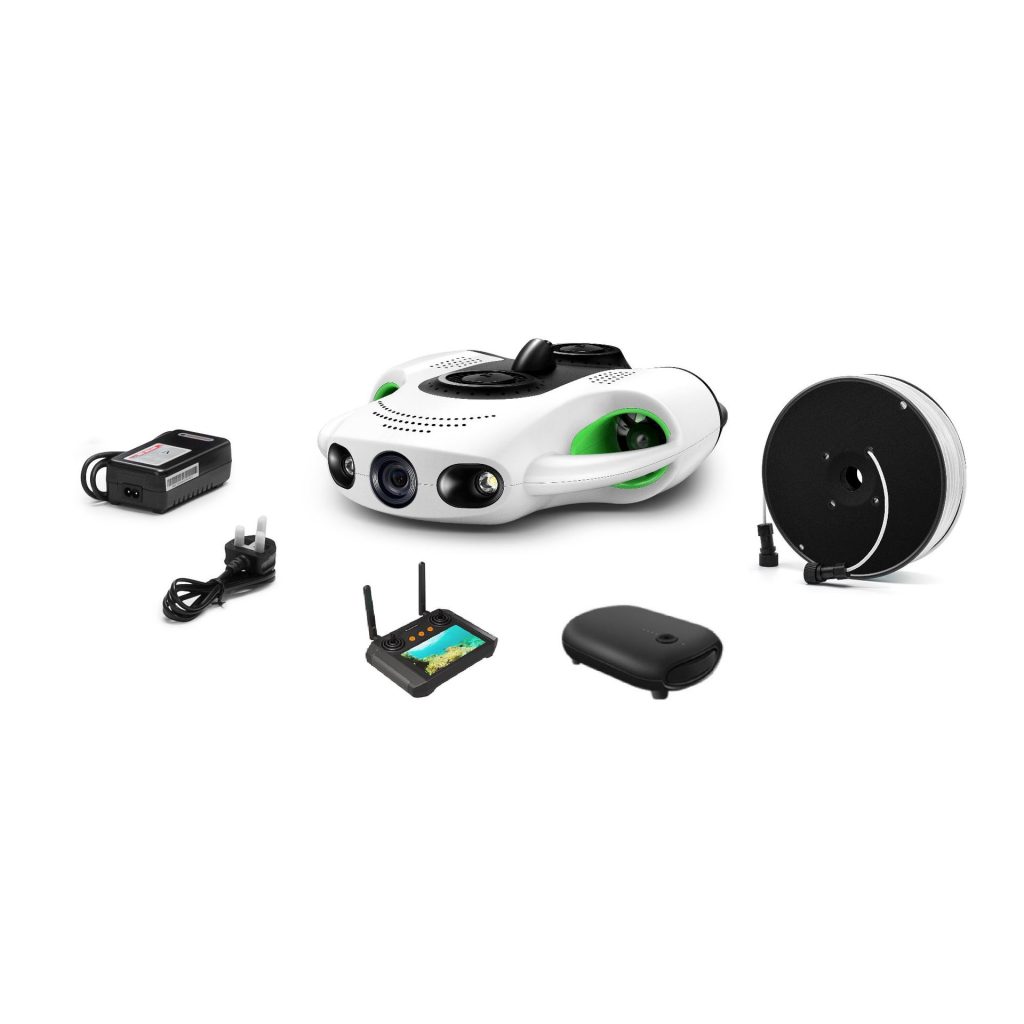
Modern underwater drones are no longer just camera platforms with thrusters. They are integrated sensing systems that combine:
- Multibeam or imaging sonar
- Inertial navigation systems (INS)
- Doppler Velocity Log (DVL)
- Real-time obstacle detection algorithms
- Sensor fusion processing
- Adaptive path-planning control
This article explains how intelligent obstacle avoidance and sonar-based positioning systems form the core of what we call “deep-sea navigation technology,” and why it is transforming underwater inspection, search, and industrial operations.
Section 1: The Challenge of Underwater Navigation
1.1 No GPS Environment
Unlike aerial drones, underwater drones operate in a GPS-denied environment. Once submerged beyond a few centimeters, satellite signals disappear. That means positioning must rely on internal and acoustic systems.
1.2 Limited Visibility
Light attenuates rapidly underwater. Even high-lumen LED arrays cannot compensate for suspended sediment in reservoirs or coastal environments.
1.3 Dynamic Currents and Drift
Water movement introduces continuous drift forces. Without correction, a vehicle may deviate significantly from its intended path.
1.4 Complex Structures
Industrial environments contain:
- Steel reinforcement
- Concrete surfaces
- Nets and cables
- Anchors
- Debris
Collision risk is high without real-time sensing.
This is where intelligent obstacle avoidance + sonar localization become essential.
Section 2: Intelligent Obstacle Avoidance – Beyond Simple Sensors
Many entry-level underwater drones advertise “obstacle avoidance,” but in practice they rely on basic proximity sensors.
True intelligent avoidance involves:
- Multi-directional sonar scanning
- Dynamic object classification
- Predictive trajectory modeling
- Closed-loop control feedback
2.1 Sonar-Based Obstacle Detection
Unlike optical cameras, sonar does not depend on light. It uses acoustic waves to map surroundings.
Common Sonar Types Used:
- Imaging Sonar (High Frequency, e.g., 900kHz – 1.2MHz)
- Multibeam Sonar
- Forward-Looking Sonar (FLS)
Higher frequency provides higher resolution but shorter range. Lower frequency increases range but reduces detail.
Typical industrial configuration:
| Parameter | Typical Value |
|---|---|
| Sonar Frequency | 900 kHz |
| Detection Range | 0.5 – 50 meters |
| Angular Resolution | 1° – 2° |
| Beam Count | 128 – 512 beams |
| Update Rate | 10–20 Hz |
This allows the drone to build a real-time acoustic map.
2.2 SLAM in Underwater Robotics
Simultaneous Localization and Mapping (SLAM) is widely used in autonomous vehicles. Underwater, it becomes more complex.
Acoustic SLAM combines:
- Sonar returns
- Inertial data
- Velocity logs
The algorithm builds a continuously updating map while estimating the vehicle’s position relative to that map.
Key processing methods include:
- Extended Kalman Filtering (EKF)
- Particle filtering
- Graph-based optimization
This prevents cumulative drift.
2.3 Predictive Obstacle Avoidance
Basic avoidance stops when something is detected.
Intelligent avoidance predicts motion.
For example:
If current velocity = 0.8 m/s
Vehicle speed = 1.5 m/s
Obstacle detected at 5m
The system calculates:
- Drift vector
- Time-to-collision
- Safe path deviation angle
Control commands are adjusted automatically.
Section 3: Sonar-Based Positioning – The Core of Deep-Sea Navigation
Without GPS, underwater positioning relies on acoustic methods and inertial estimation.
3.1 Inertial Navigation System (INS)
INS uses:
- Accelerometers
- Gyroscopes
- Magnetometers
It estimates position through integration of acceleration data.
However, drift accumulates over time.
3.2 Doppler Velocity Log (DVL)
DVL measures velocity relative to the seabed using acoustic Doppler shift.
Typical technical parameters:
| Parameter | Specification |
|---|---|
| Frequency | 600 kHz – 1 MHz |
| Velocity Accuracy | ±0.2% |
| Max Altitude | 50m above seabed |
| Update Rate | 5–20 Hz |
By combining DVL velocity with INS, position drift is significantly reduced.
3.3 Acoustic Positioning Systems
For larger-scale operations:
- Ultra-Short Baseline (USBL)
- Long Baseline (LBL)
These systems use triangulation from acoustic transponders.
Section 4: Sensor Fusion – The Real Intelligence Layer
Raw sensor data is not enough.
Modern underwater drones rely on multi-sensor fusion architecture.
Data Inputs:
- Sonar
- INS
- DVL
- Depth sensor (pressure-based)
- Compass
- Thruster feedback
Fusion Method:
Kalman filtering integrates all data streams into a unified state estimate.
Output includes:
- Position
- Orientation
- Velocity
- Obstacle proximity
This creates stable navigation even in zero-visibility water.
Section 5: Technical Specification Overview – Deep-Sea Navigation System
Below is a representative configuration for an industrial underwater drone equipped with intelligent navigation:
| Category | Specification |
|---|---|
| Max Depth Rating | 300 meters |
| Navigation Type | Acoustic + Inertial Fusion |
| Sonar Type | Forward-Looking Multibeam |
| Sonar Range | Up to 50m |
| DVL Accuracy | ±0.2% |
| Position Drift | < 1% of distance traveled |
| Obstacle Detection Angle | 120° horizontal |
| Reaction Time | < 100 ms |
| Thruster Configuration | 6-vector layout |
| Max Speed | 2 knots |
| Stabilization | 6-DOF closed-loop control |
| Power Supply | Tethered / Hybrid |
| Operating Temp | -10°C to 45°C |
Section 6: Comparison – Basic Underwater Drone vs Intelligent Navigation System
| Feature | Basic Model | Intelligent Navigation Model |
|---|---|---|
| Obstacle Avoidance | Proximity-based | Sonar + Predictive |
| Positioning | Manual estimation | INS + DVL + SLAM |
| Drift Control | Limited | Continuous correction |
| Mapping | No | Real-time acoustic mapping |
| Industrial Use | Hobby / Shallow | Professional inspection |
| Safety | Operator dependent | Autonomous correction |
The difference becomes obvious in:
- Turbid reservoirs
- Night operations
- Dam wall inspections
- Offshore structure surveys
Section 7: Real Industrial Applications
Dam Inspection
Concrete crack detection combined with sonar mapping ensures no blind spots.
Offshore Pipeline Survey
Sonar detects sediment coverage and free spans.
Aquaculture Net Cage Monitoring
Obstacle avoidance prevents entanglement.
Search & Recovery
Precise localization shortens recovery time.
Section 8: Why Deep-Sea Navigation Defines Market Leadership
Underwater robotics is entering a phase similar to early autonomous vehicles.
Mechanical reliability is assumed.
Navigation intelligence differentiates leaders.
Buyers increasingly evaluate:
- Drift accuracy
- Sonar resolution
- Fusion stability
- Deployment simplicity
Not just camera resolution.
FAQ – Deep-Sea Navigation Technology
Q1: Why can’t underwater drones use GPS?
GPS signals cannot penetrate water effectively. Acoustic and inertial systems are required.
Q2: Is sonar affected by water turbidity?
No. Sonar uses sound waves, not light, making it effective in low visibility.
Q3: What reduces navigation drift?
Combining INS with DVL and acoustic positioning significantly reduces accumulated error.
Q4: Is intelligent obstacle avoidance fully autonomous?
Most industrial systems are semi-autonomous, assisting operators while maintaining manual override capability.
Q5: What is the main advantage of sensor fusion?
It improves stability, reduces drift, and enhances safety in complex underwater environments.
Conclusion: The Future of Underwater Robotics Is Intelligent Navigation
High-resolution cameras improve visibility.
Powerful thrusters improve mobility.
But intelligent navigation systems define capability.
Obstacle avoidance + sonar positioning + sensor fusion together form the technological backbone of modern underwater drones.
As underwater operations expand across infrastructure, aquaculture, marine energy, and environmental monitoring, systems equipped with deep-sea navigation intelligence will set the standard.
The next generation of underwater robotics will not simply move underwater.
It will understand underwater space.

No comments yet